Project documentation
MazeX — Maze Solver Robot
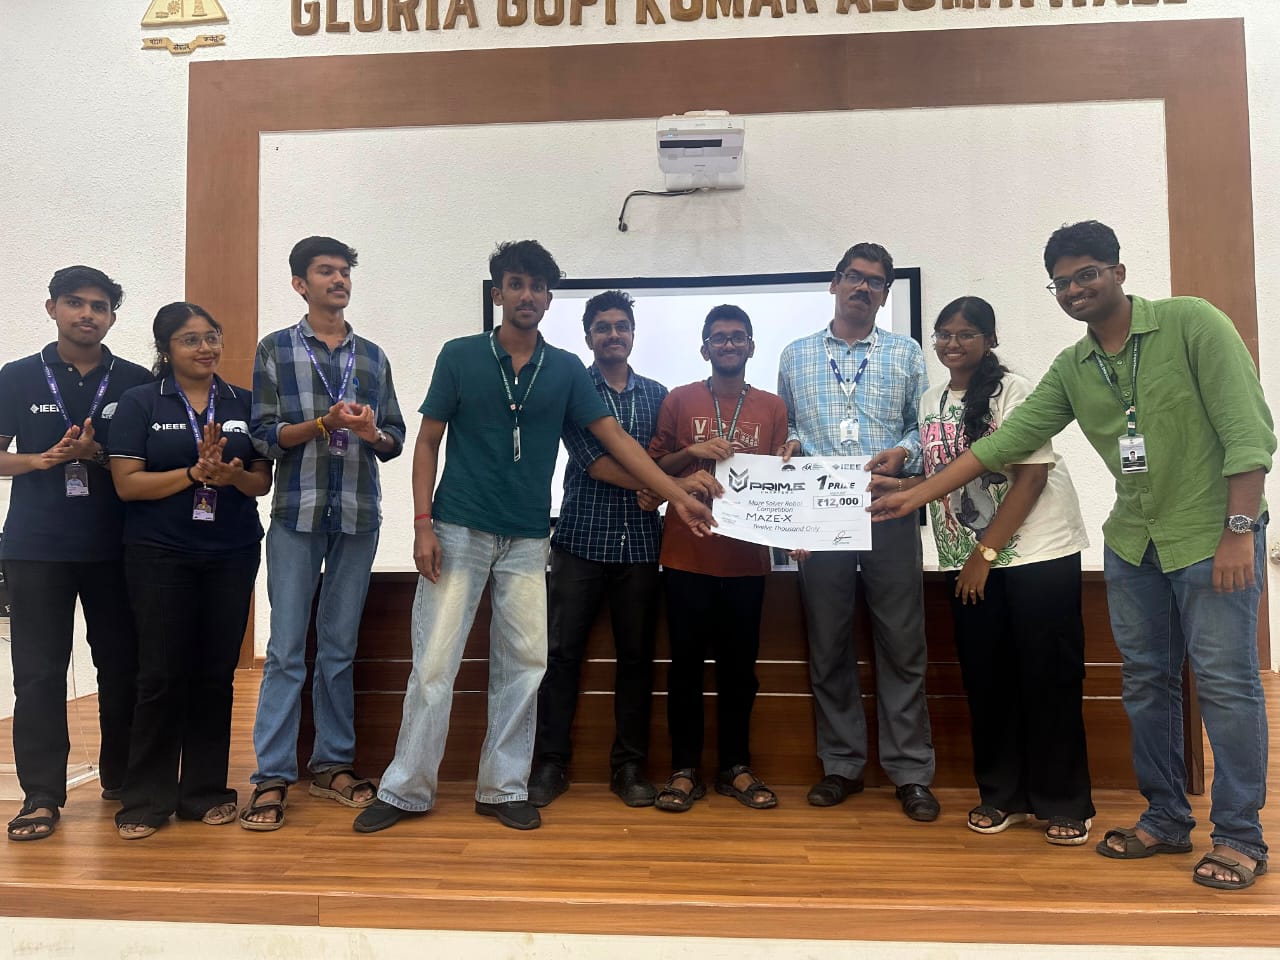
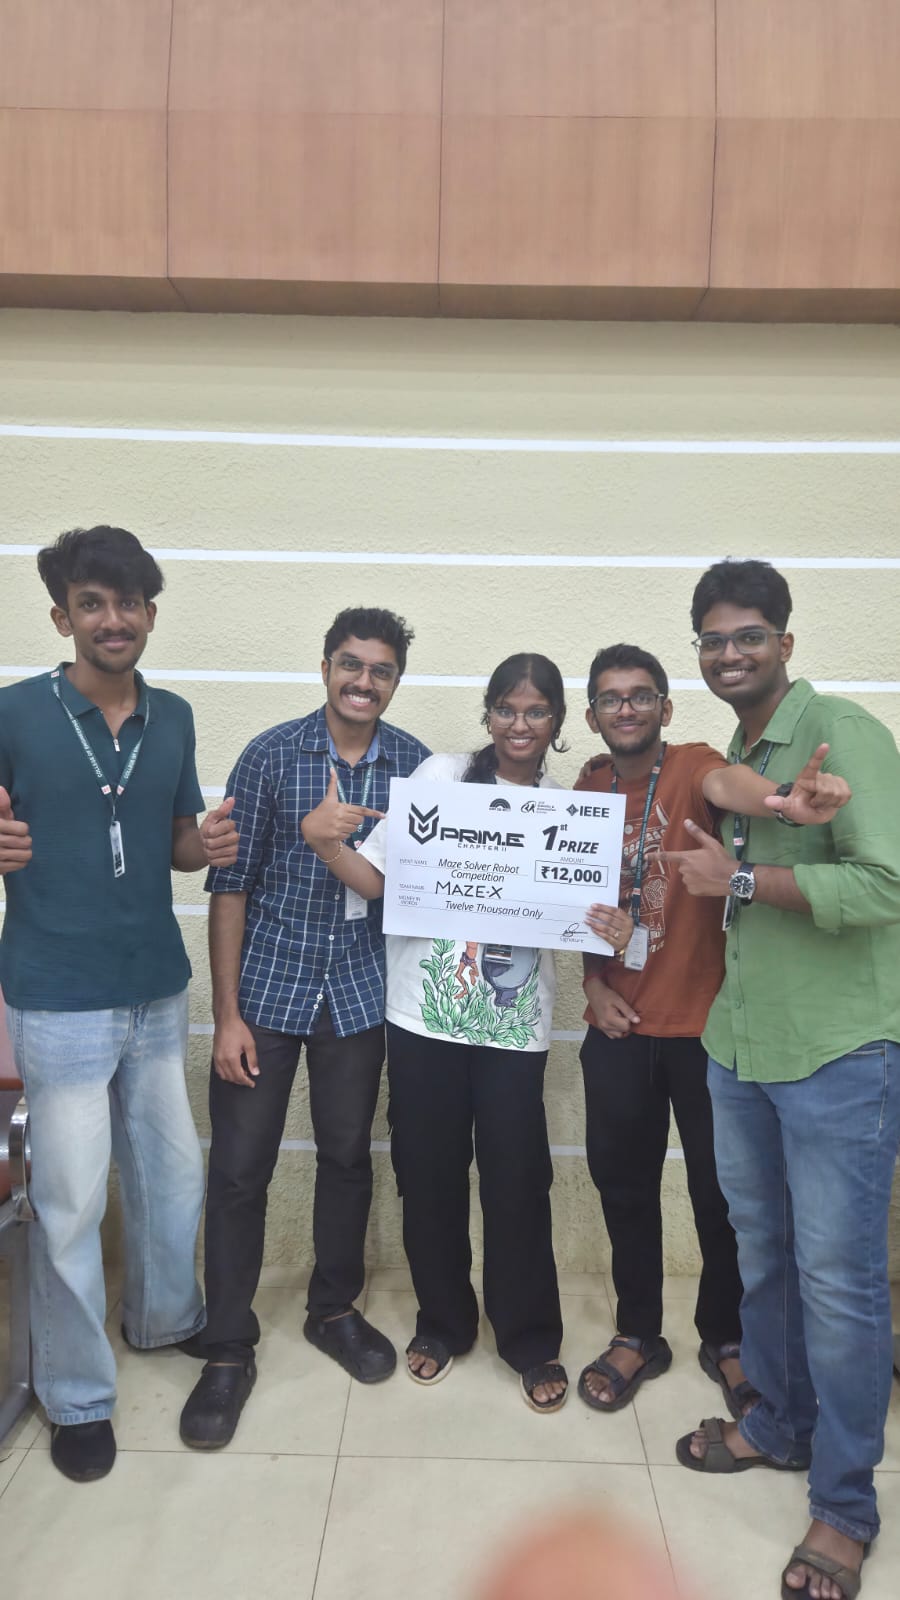
1st place · IEEE SB GECT Maze Solver Competition · GEC Thrissur
2nd place · Thatva Maze Quest · NIT Calicut
2nd place · IEEE SB CUSAT Maze Solver Competition · CUSAT
Introduction
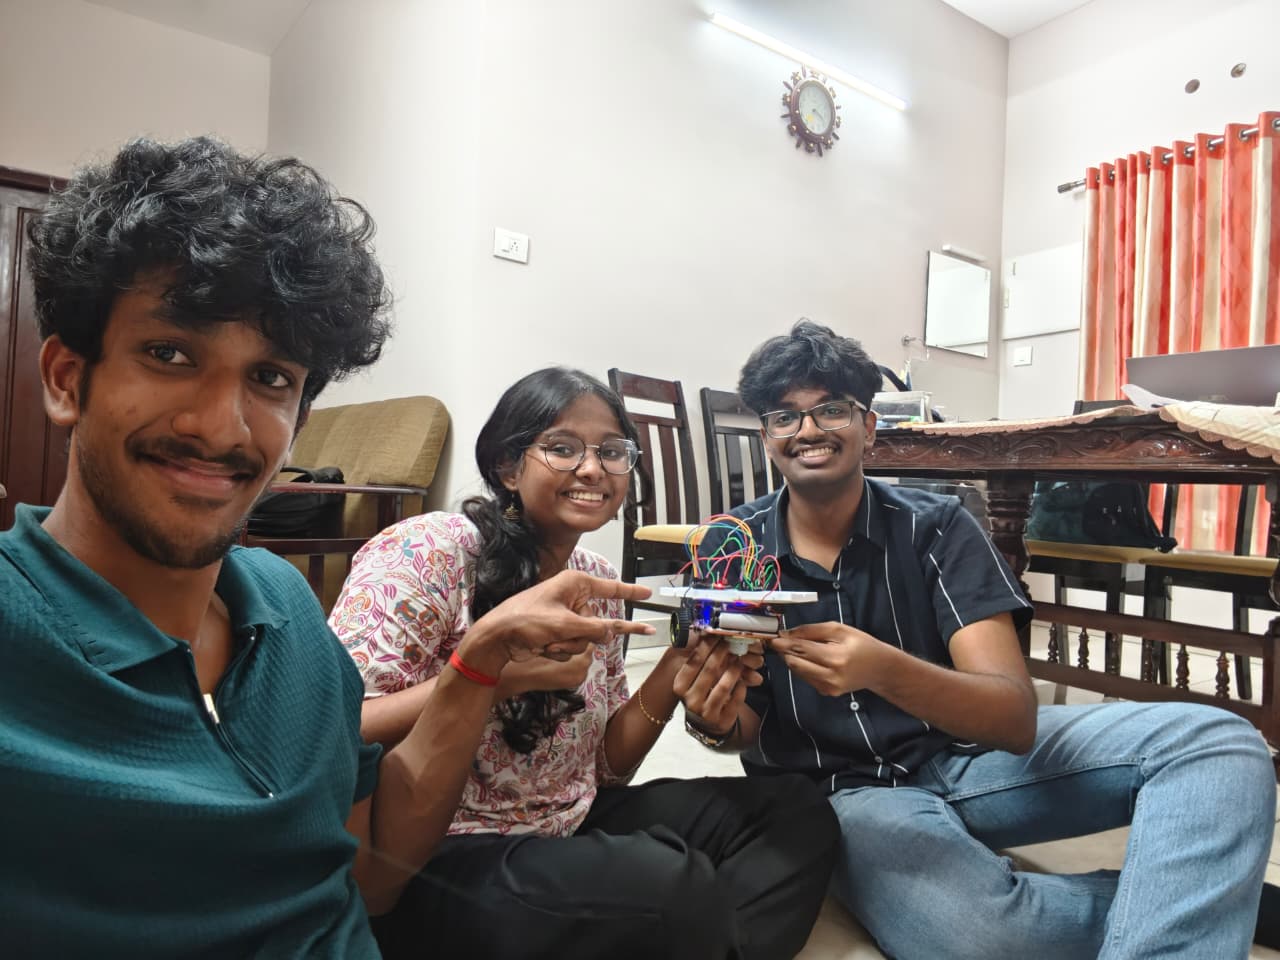
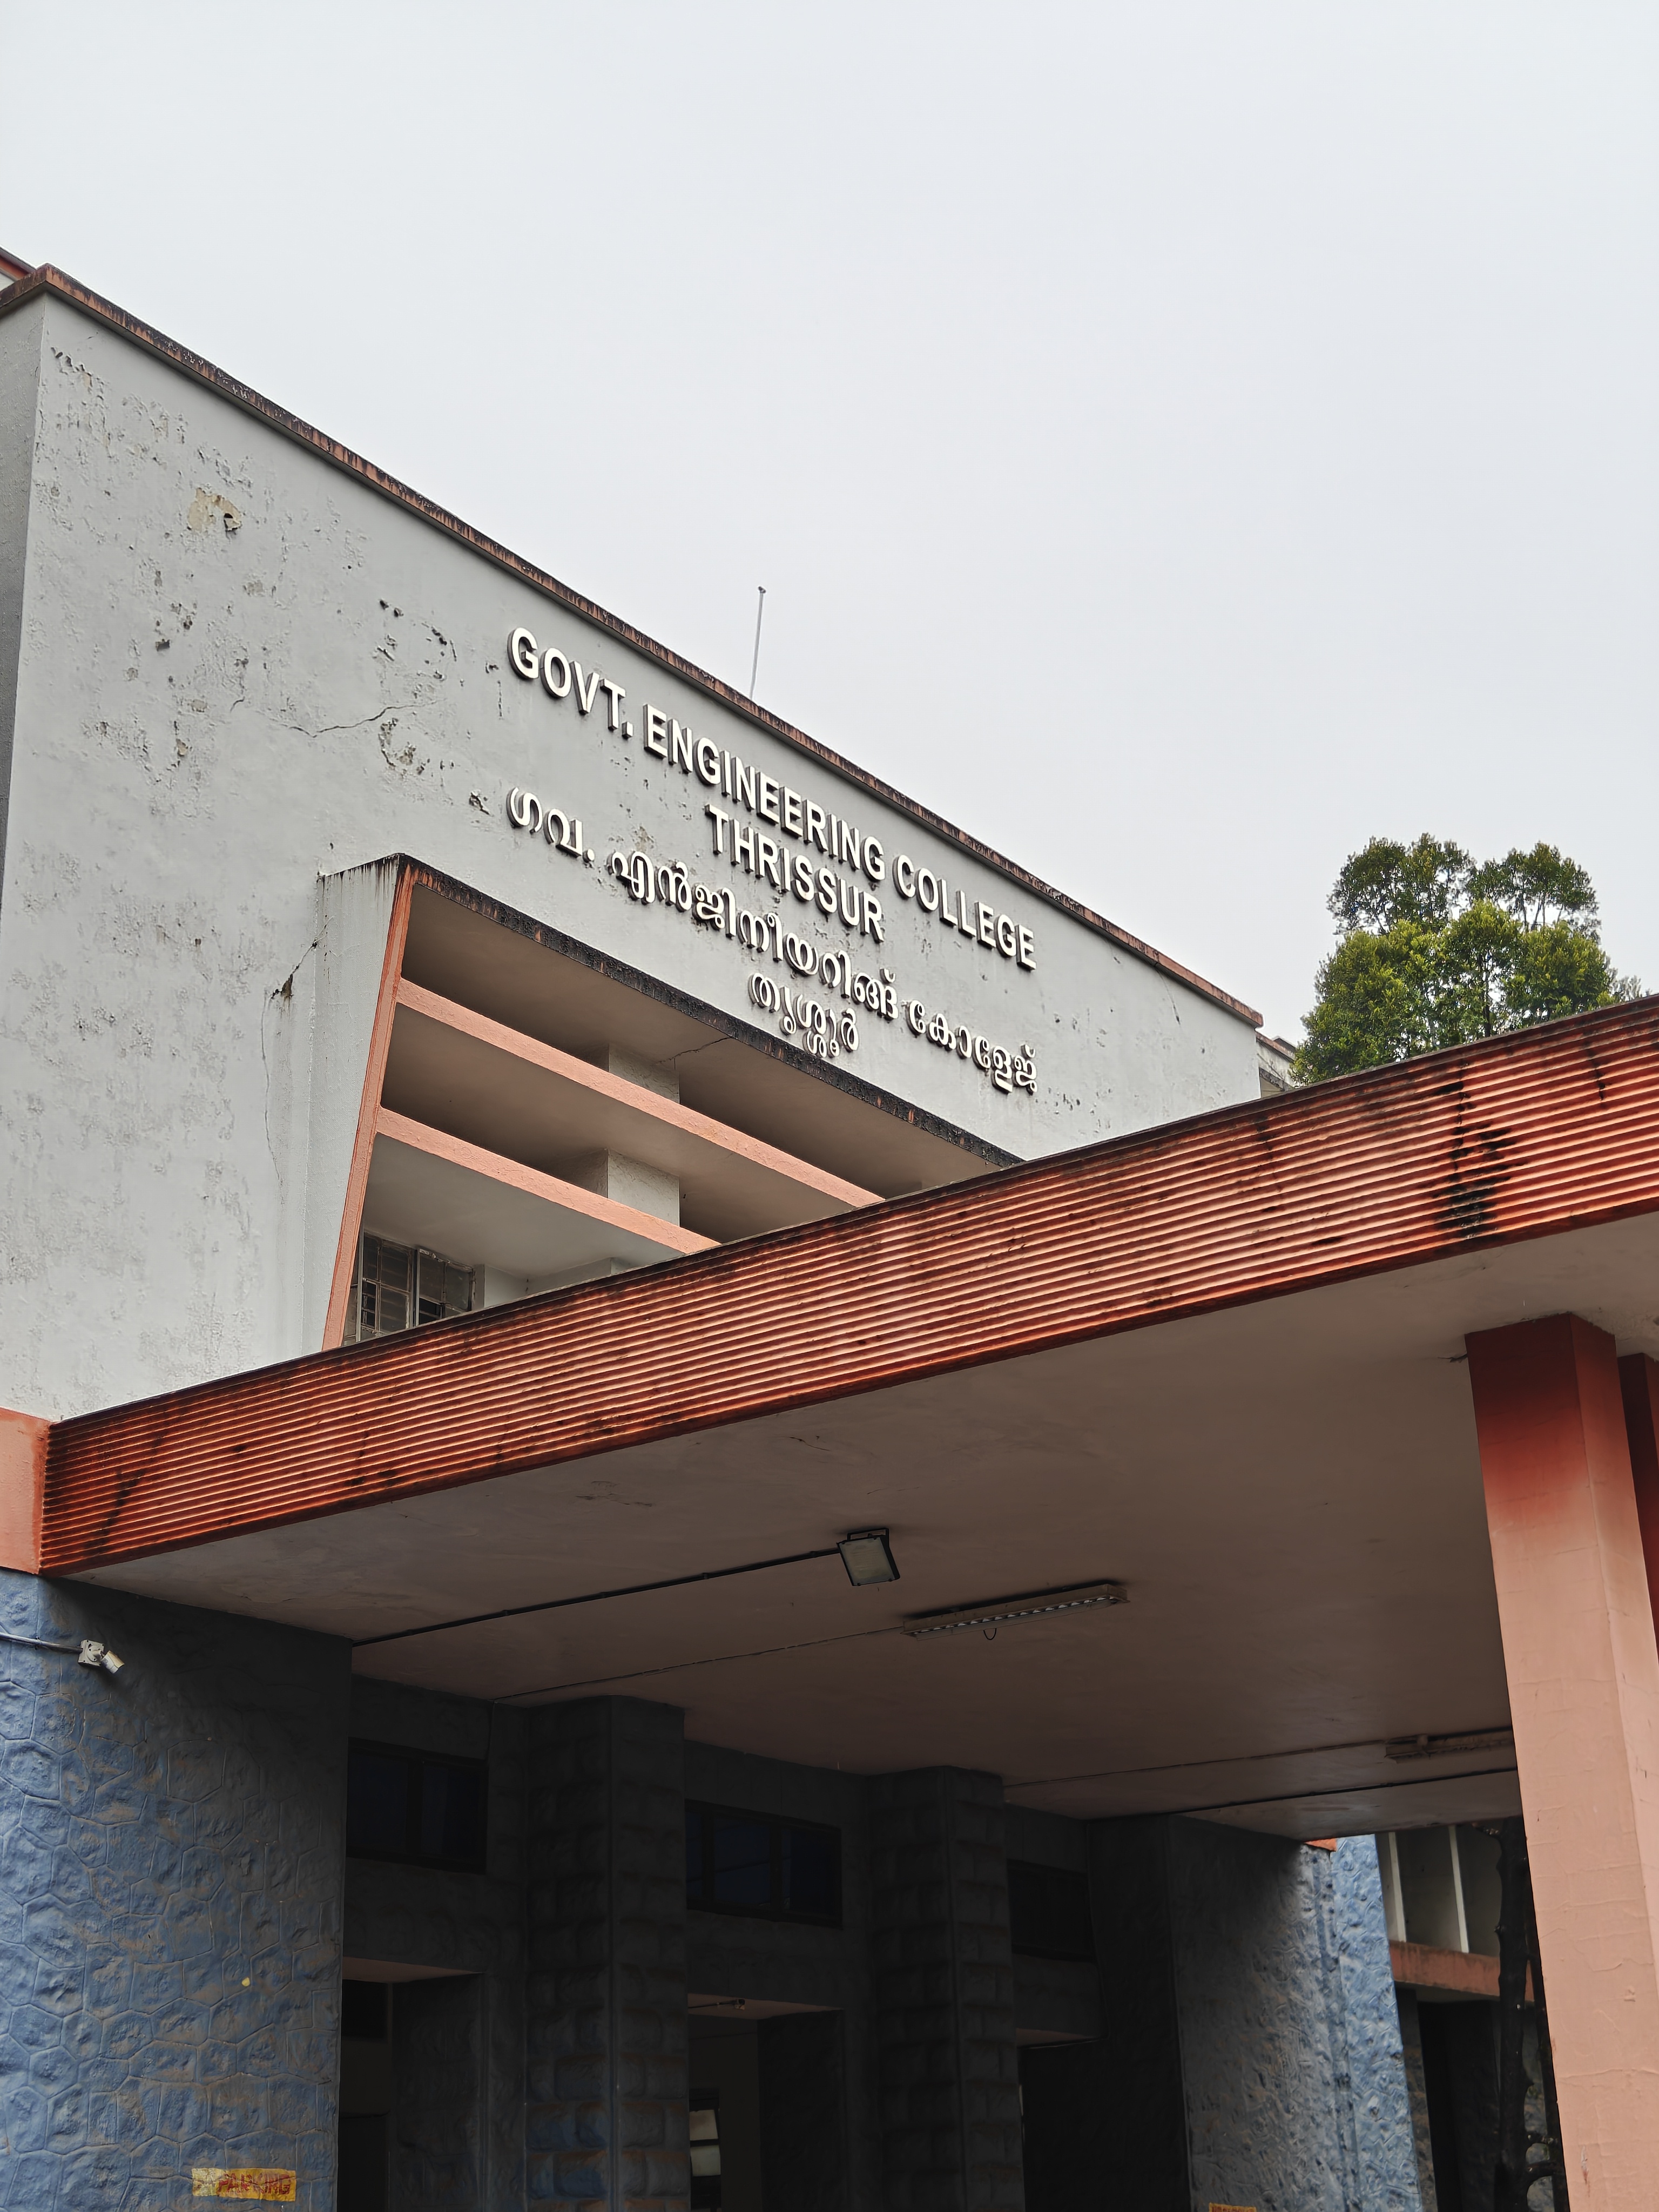
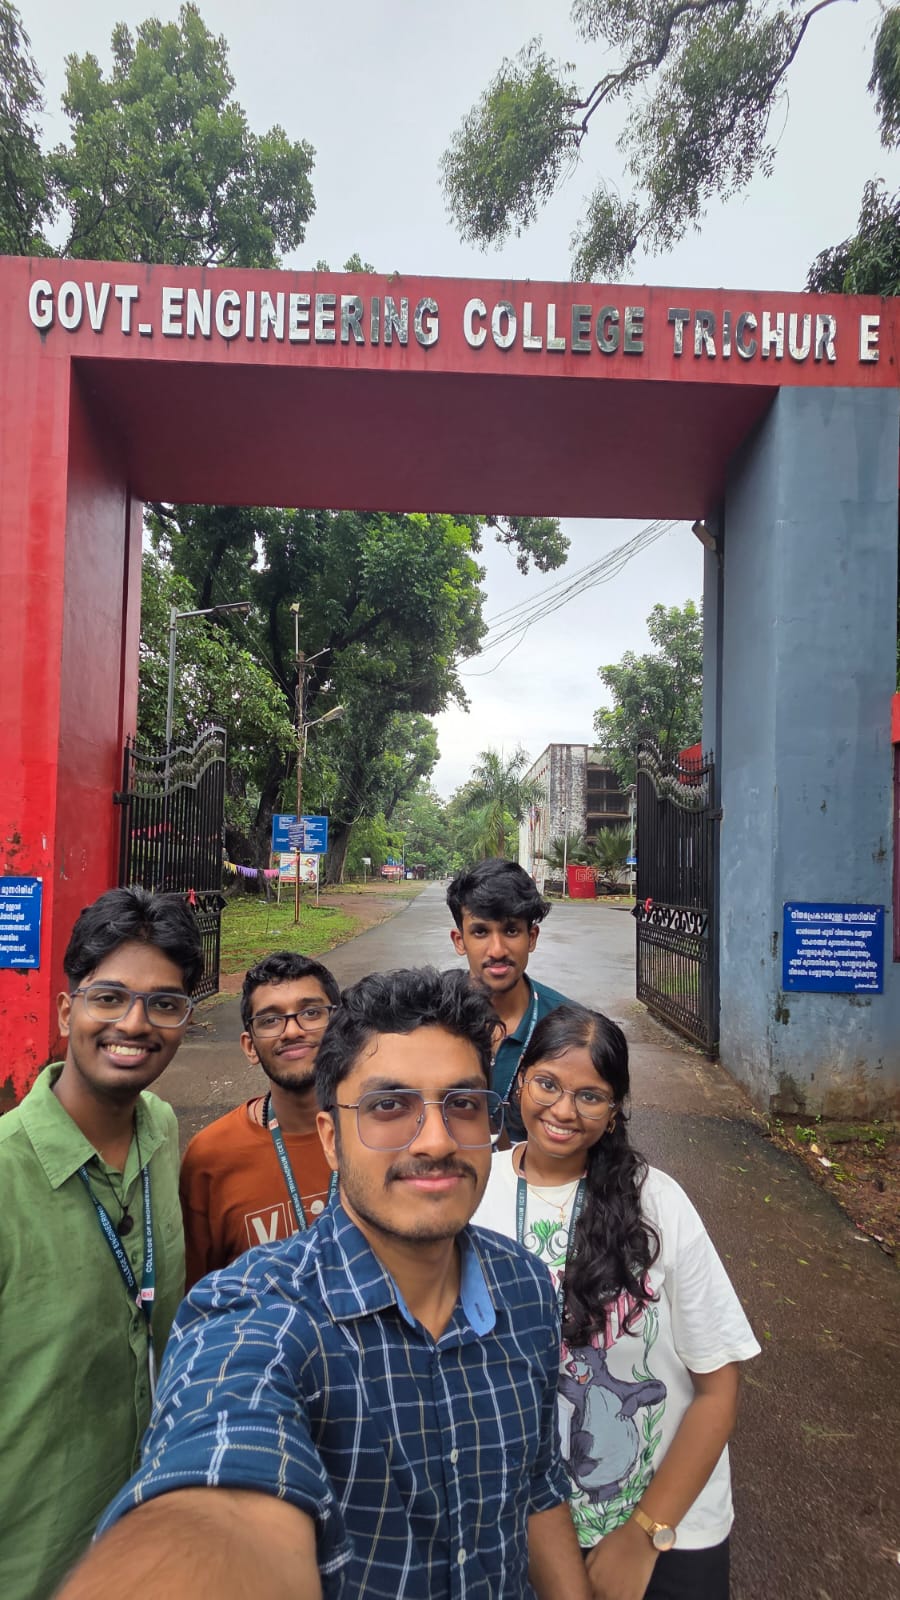
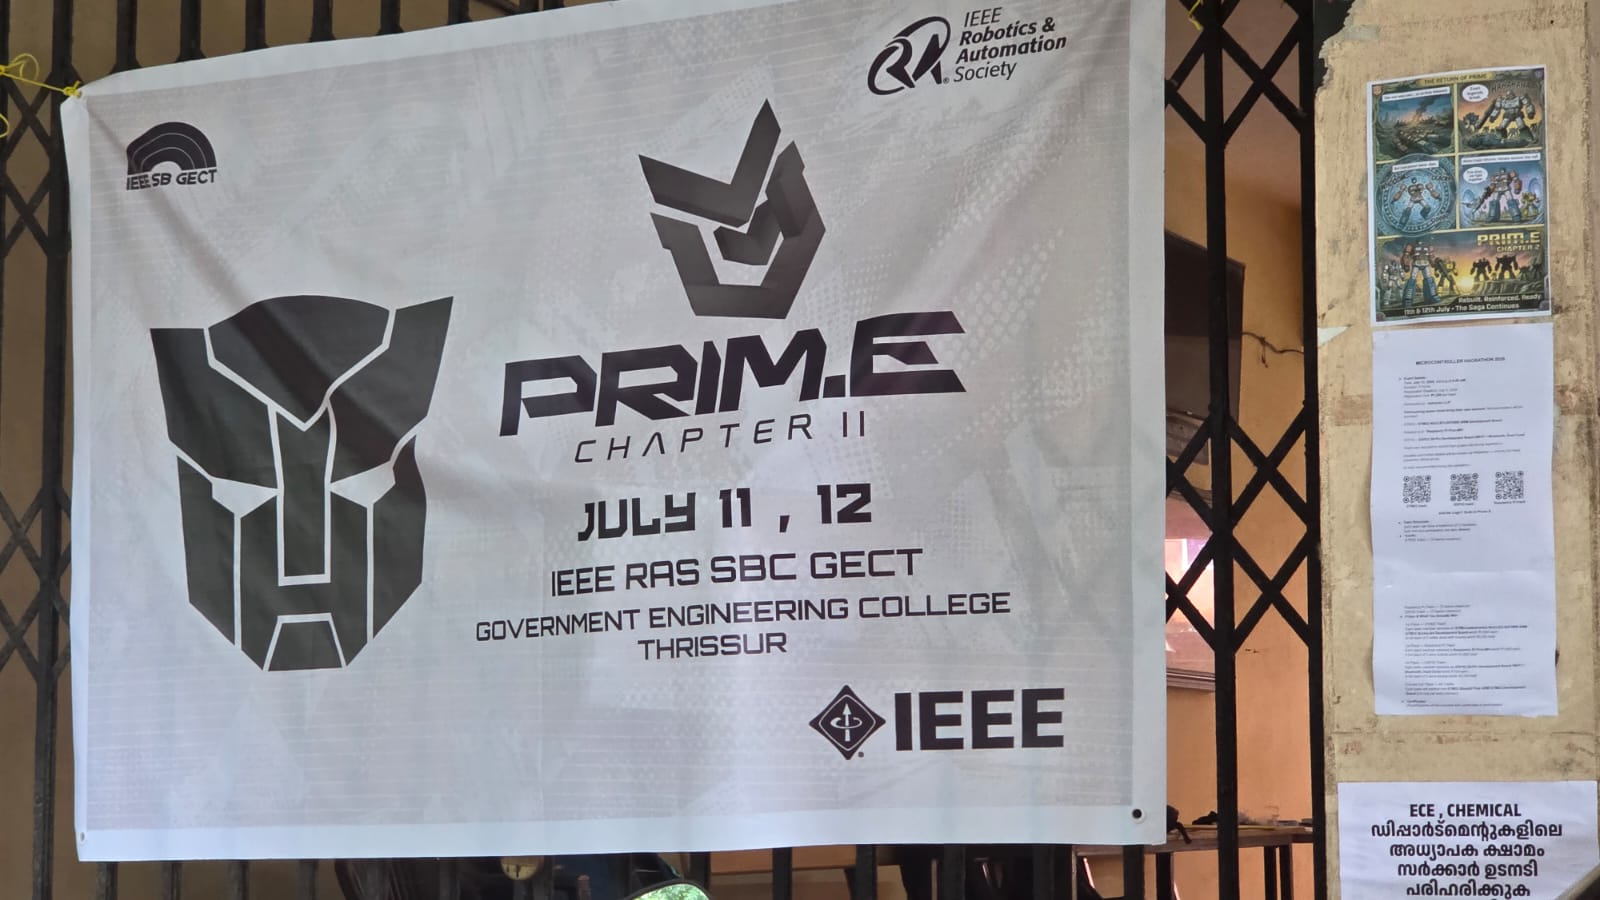
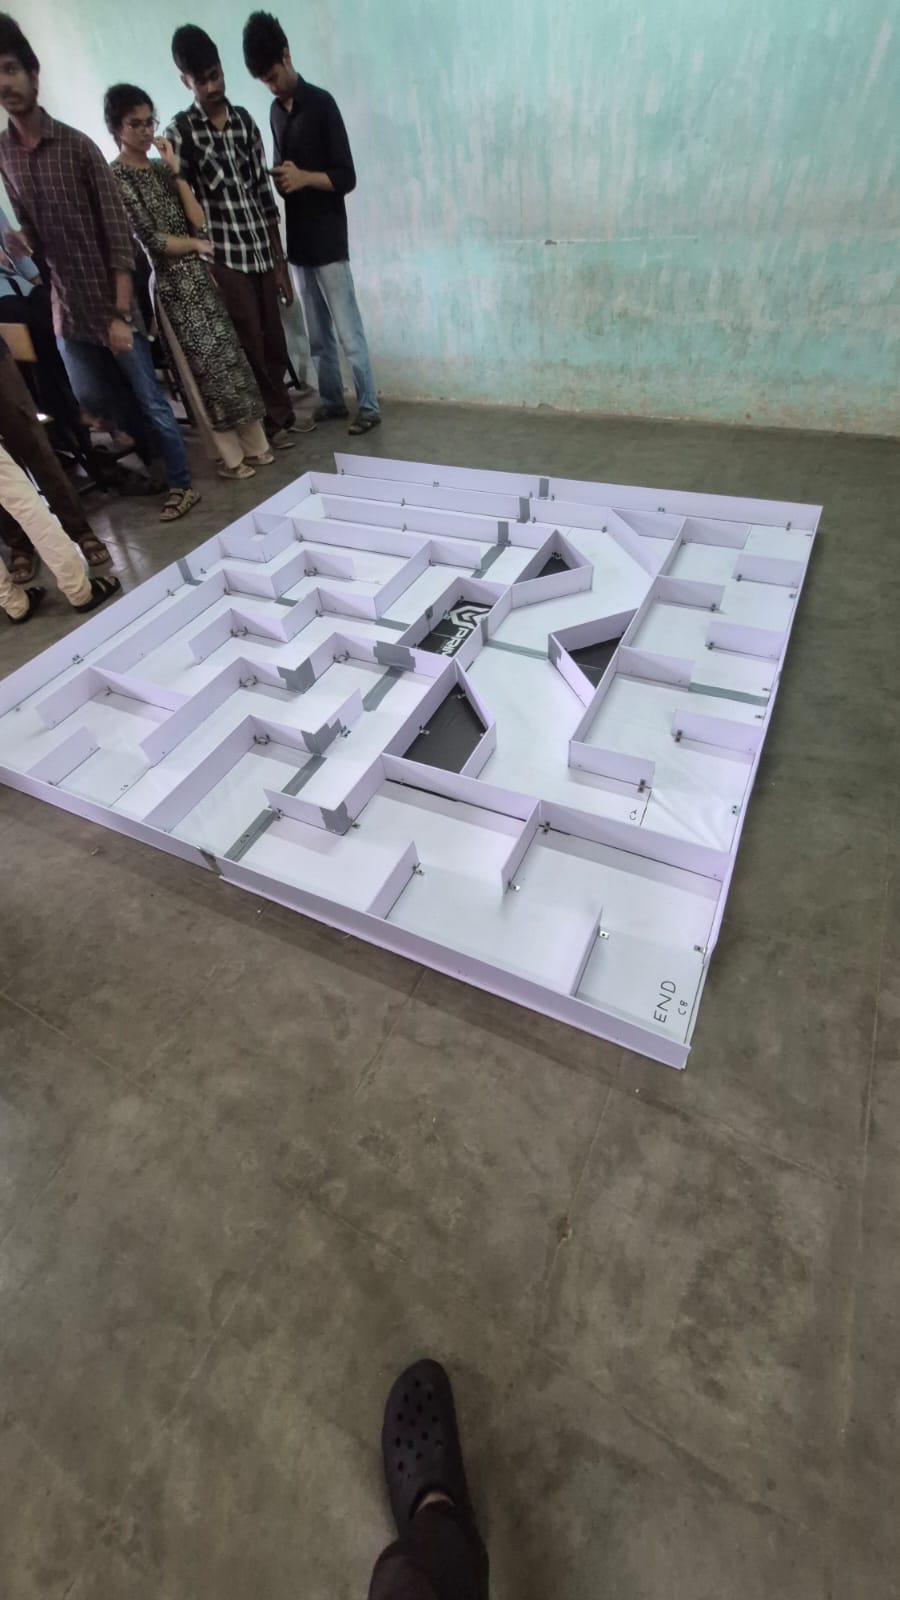
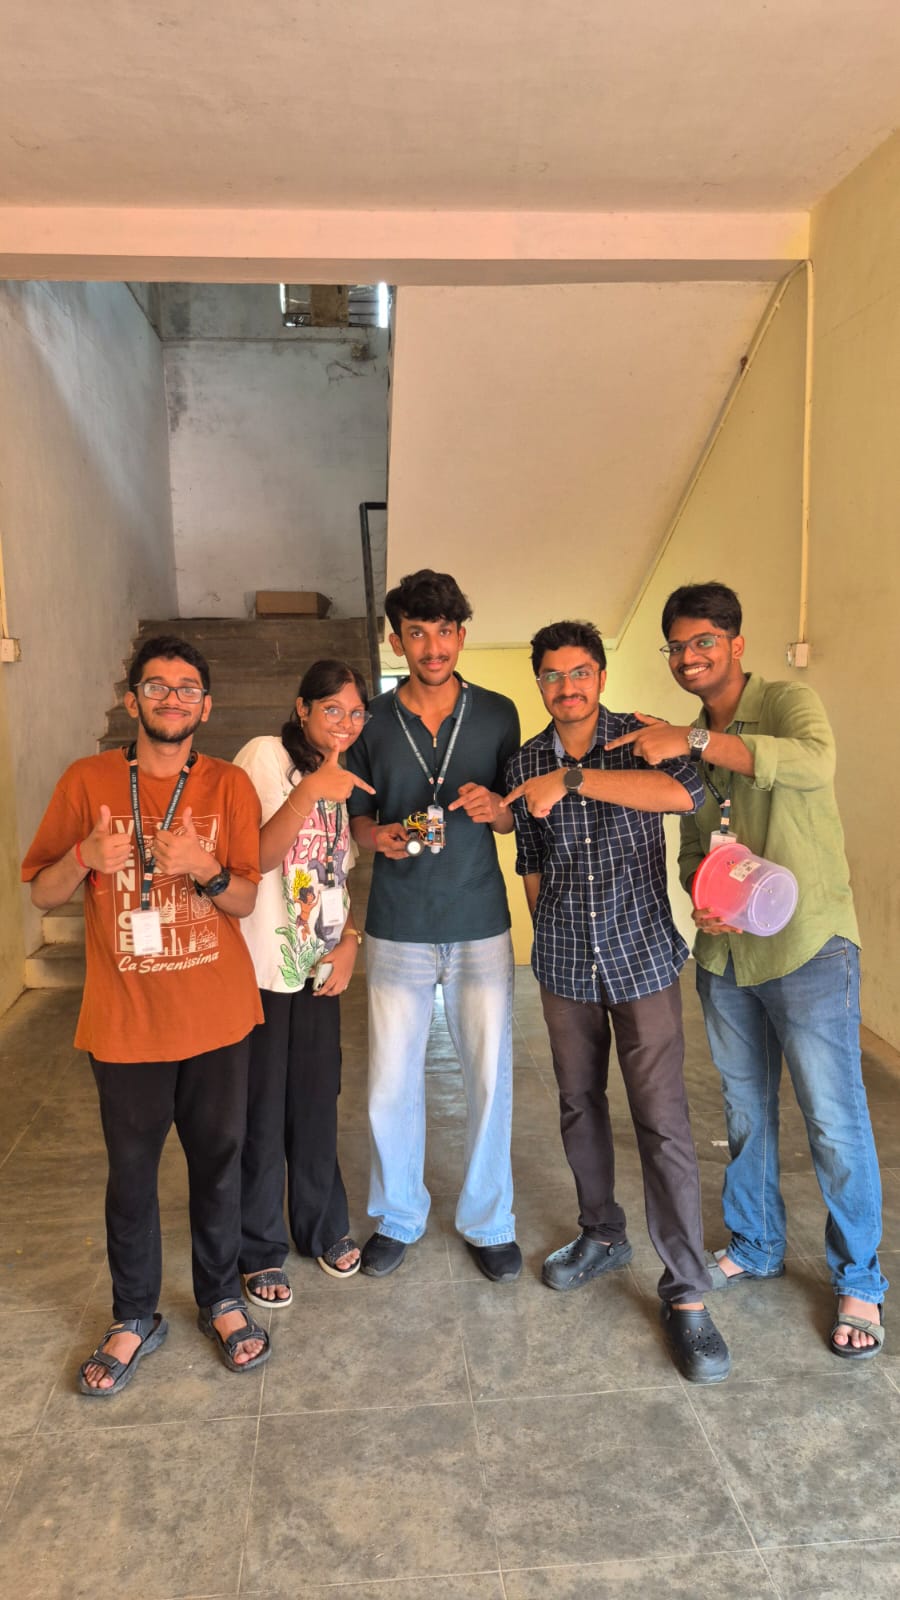
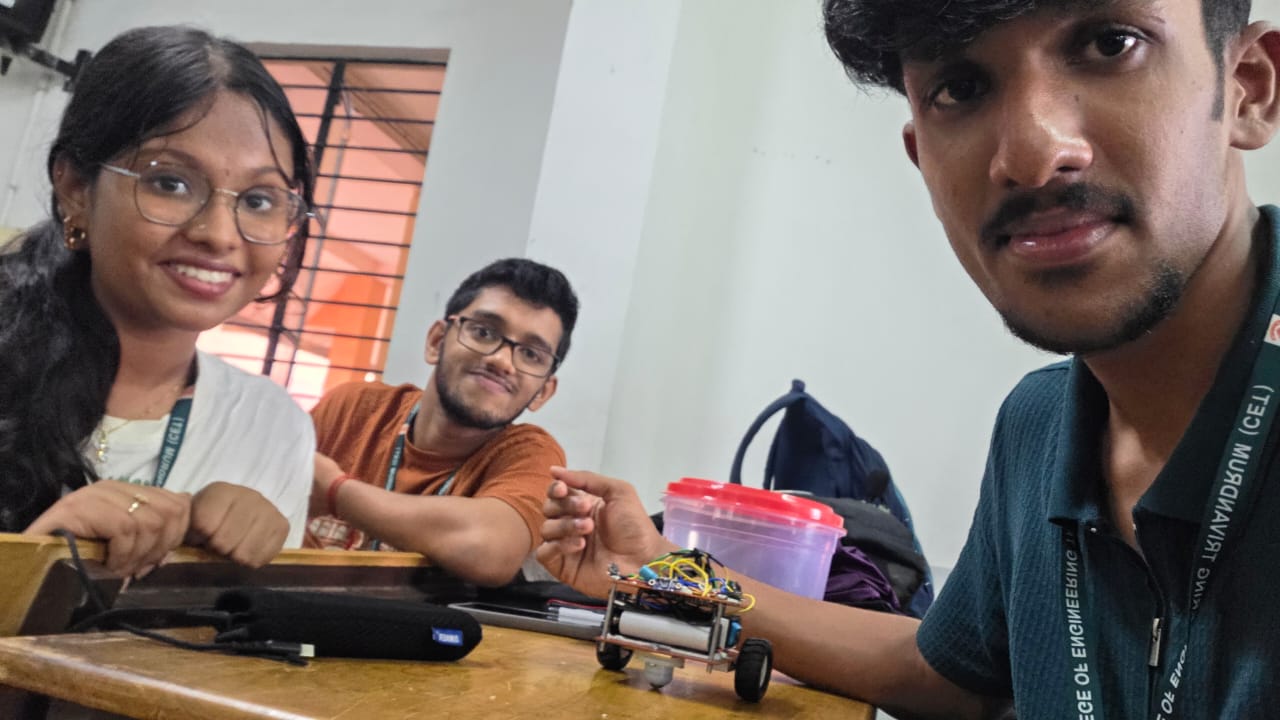
Our Team MazeX participated in Maze Solver Competitions organized by IEEE SB GECT at Government Engineering College (GEC), Thrissur, and at Cochin University of Science and Technology (CUSAT). Competing against teams from across Kerala, our robot successfully navigated challenging maze sections, securing 1st place at GEC Thrissur and 2nd place at CUSAT, showcasing our team’s technical expertise, precision, and innovative approach to robotics..
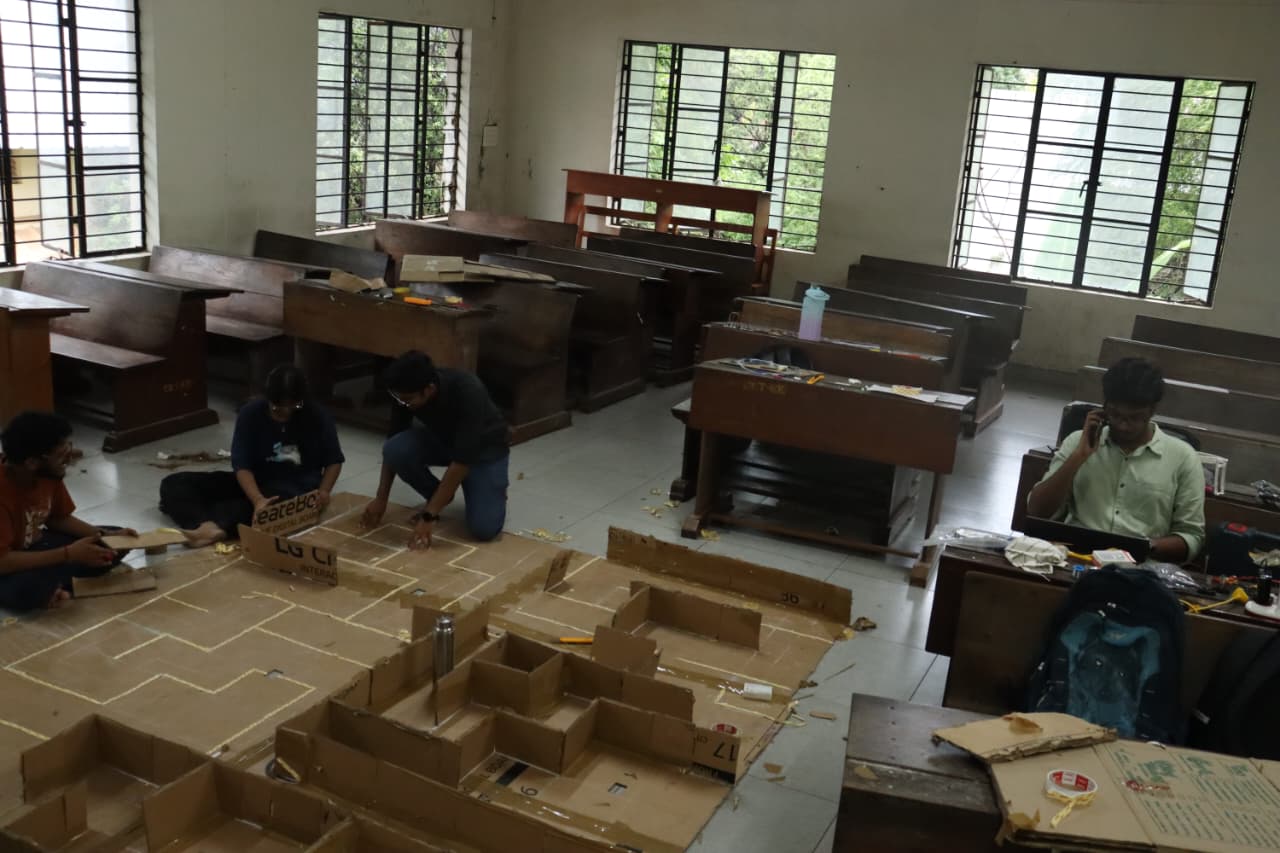
This website documents our journey, including the design, testing, and development throughout the project.
Team
Components
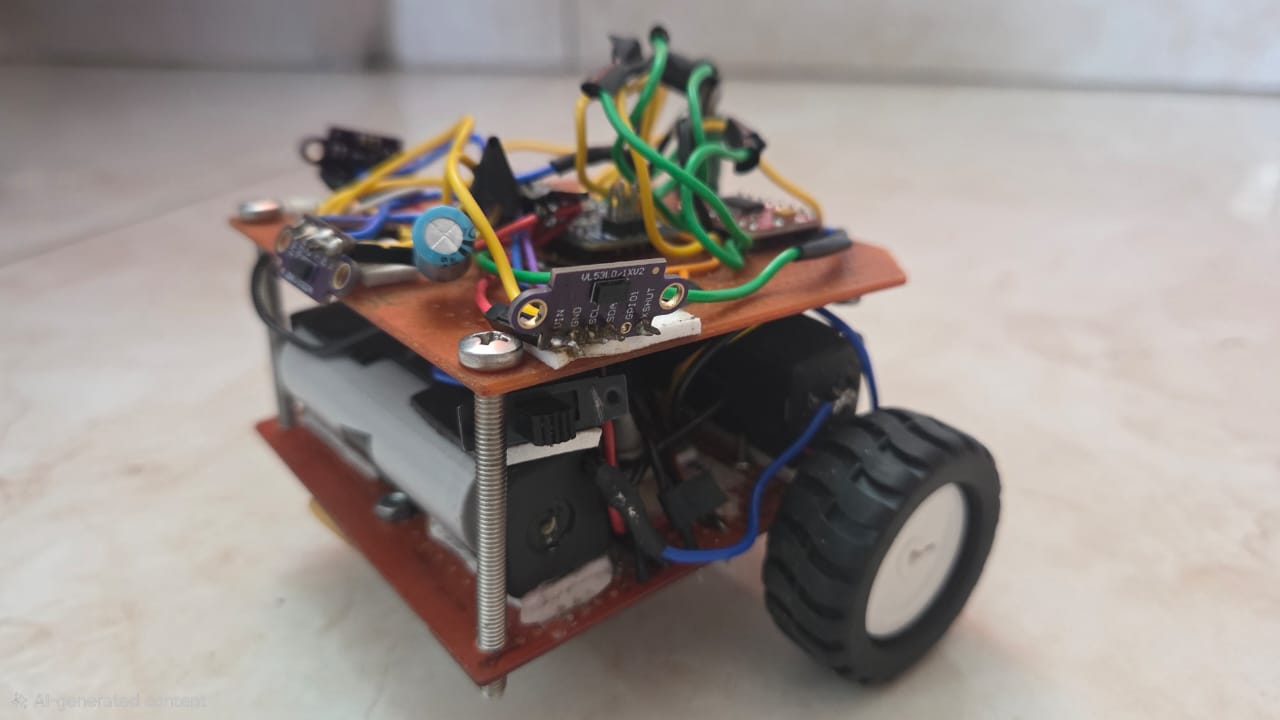
| Microcontroller | Arduino Nano V3.0 |
| Sensor | VL53L0X ToF distance sensor |
| Motor | N20 metal gear motor (6V, 600rpm) |
| Buck converter | LM2596 |
| Motor driver | TB6612FNG dual DC motor driver |
Circuit Diagram
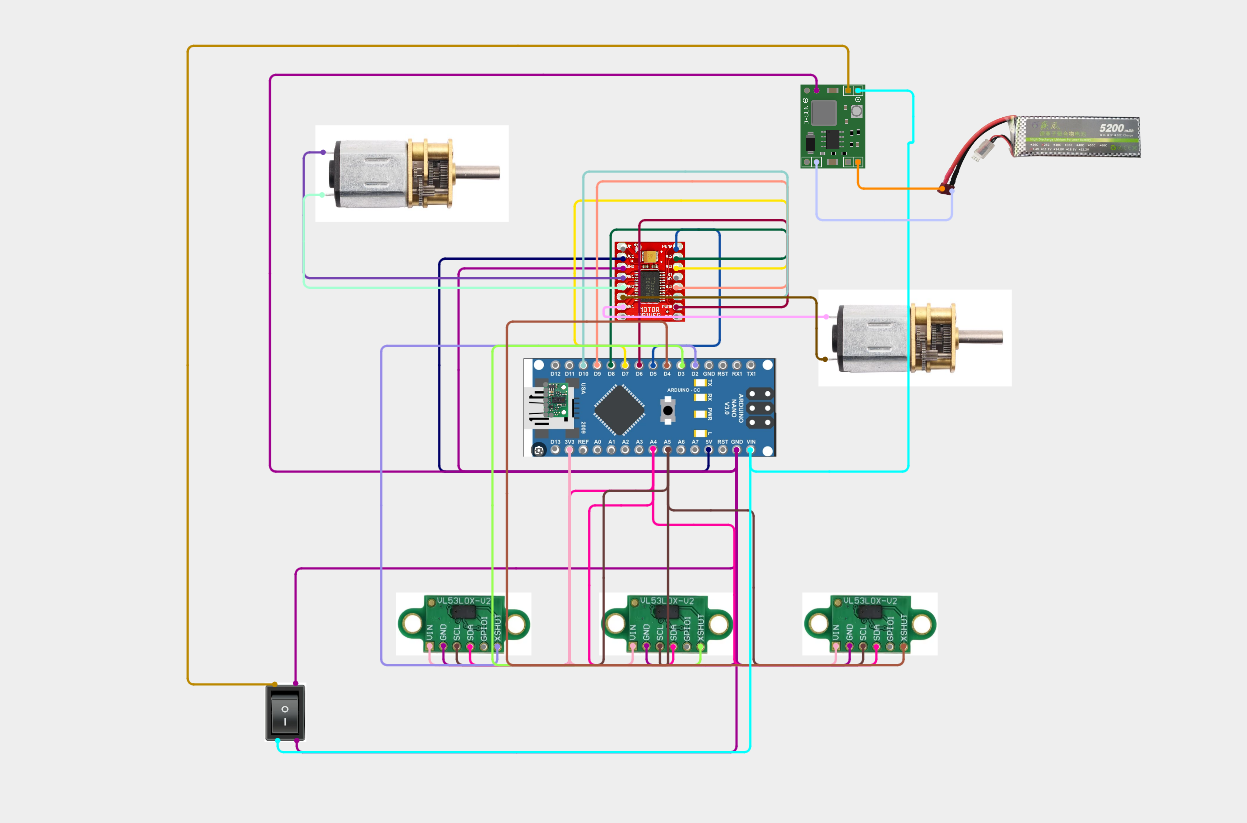
Full wiring schematic of the Mazex robot.
Open Circuit Design
Program
maze_solver.ino
C++
#include
#include

// =====================================================
// MOTOR DRIVER PINS
// =====================================================
#define STBY 4

#define PWMA 5
#define PWMB 6

#define AIN1 7
#define AIN2 8

#define BIN1 9
#define BIN2 10

// =====================================================
// VL53L0X XSHUT PINS
// =====================================================
#define XSHUT_LEFT   2
#define XSHUT_FRONT  3
#define XSHUT_RIGHT  12
CAD Design
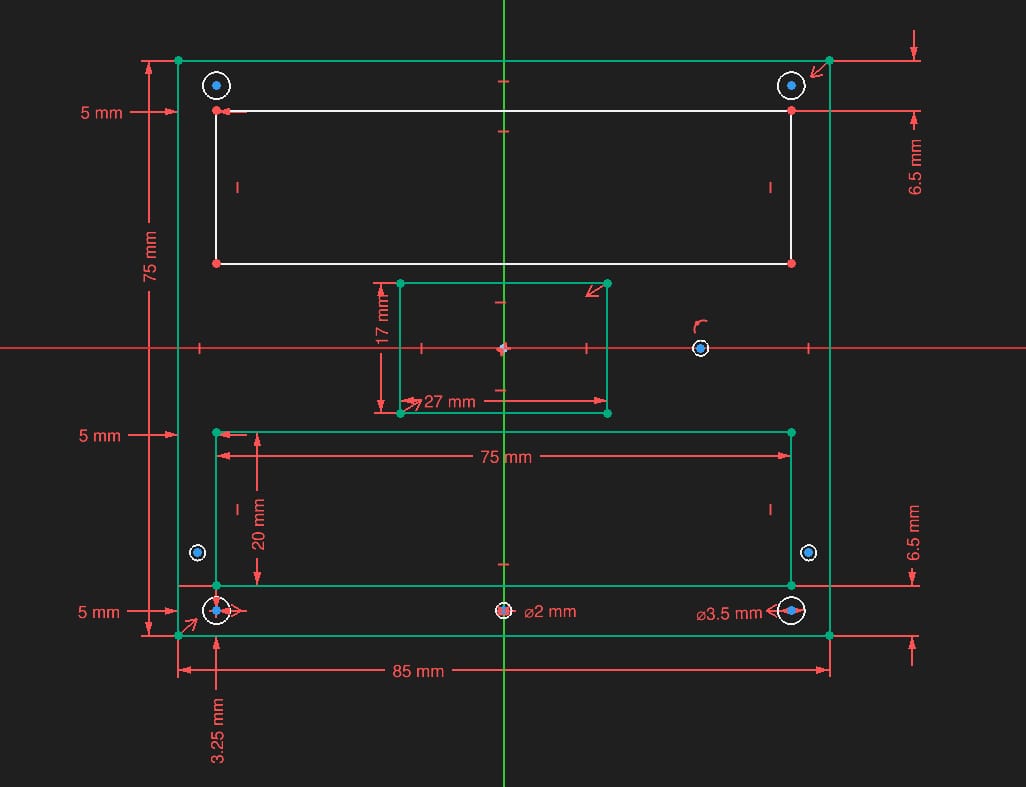
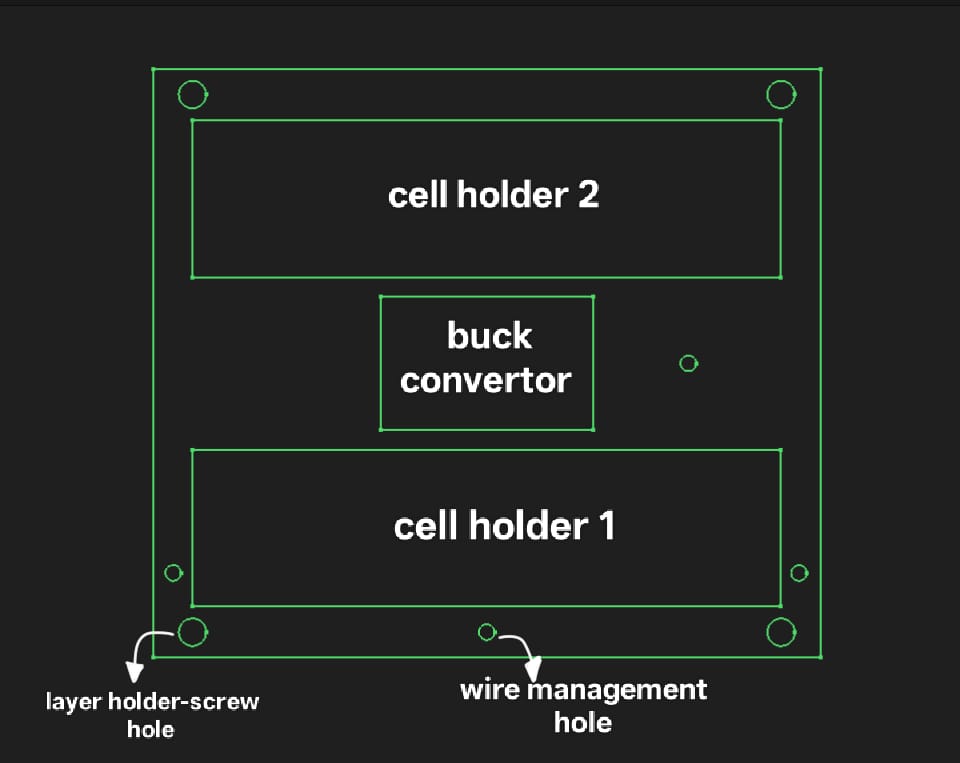
Chassis and sensor mount design.
Gallery
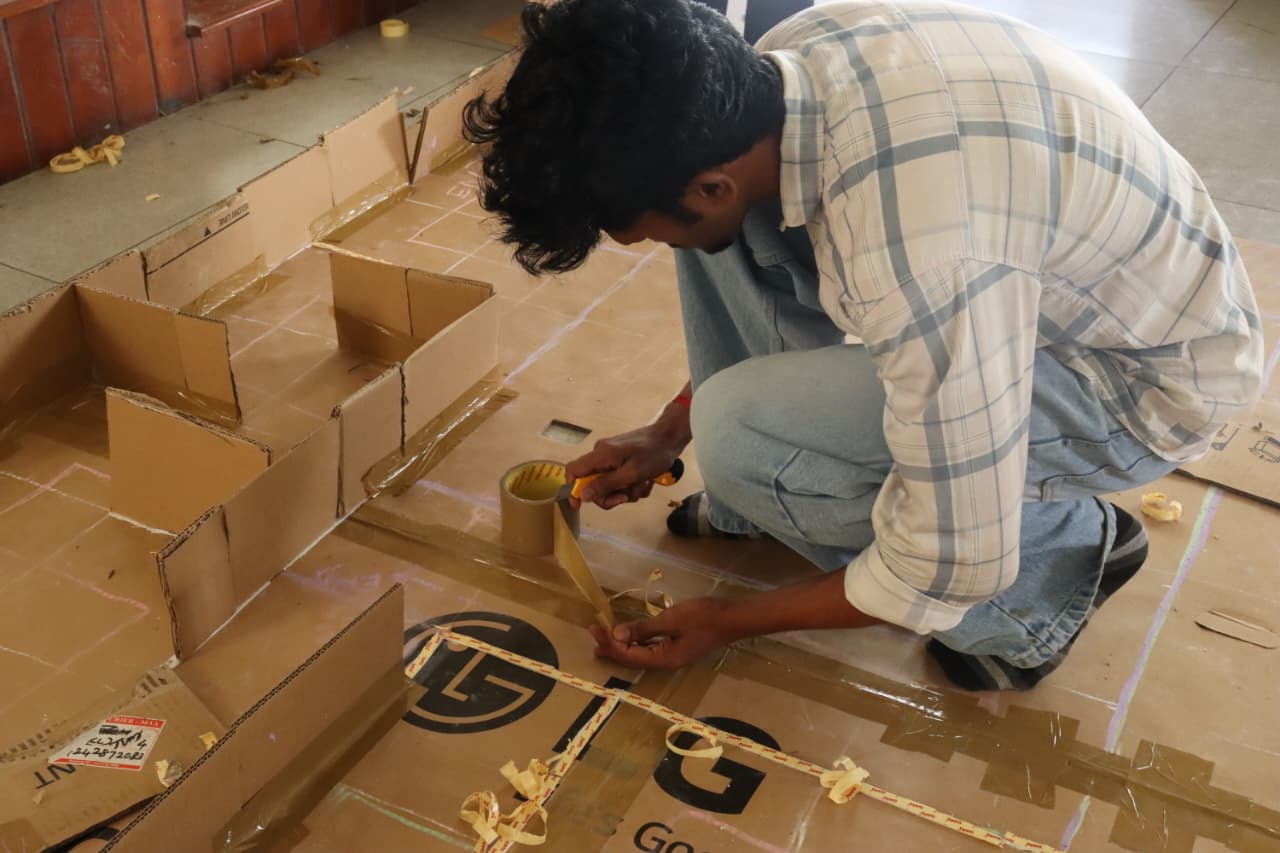
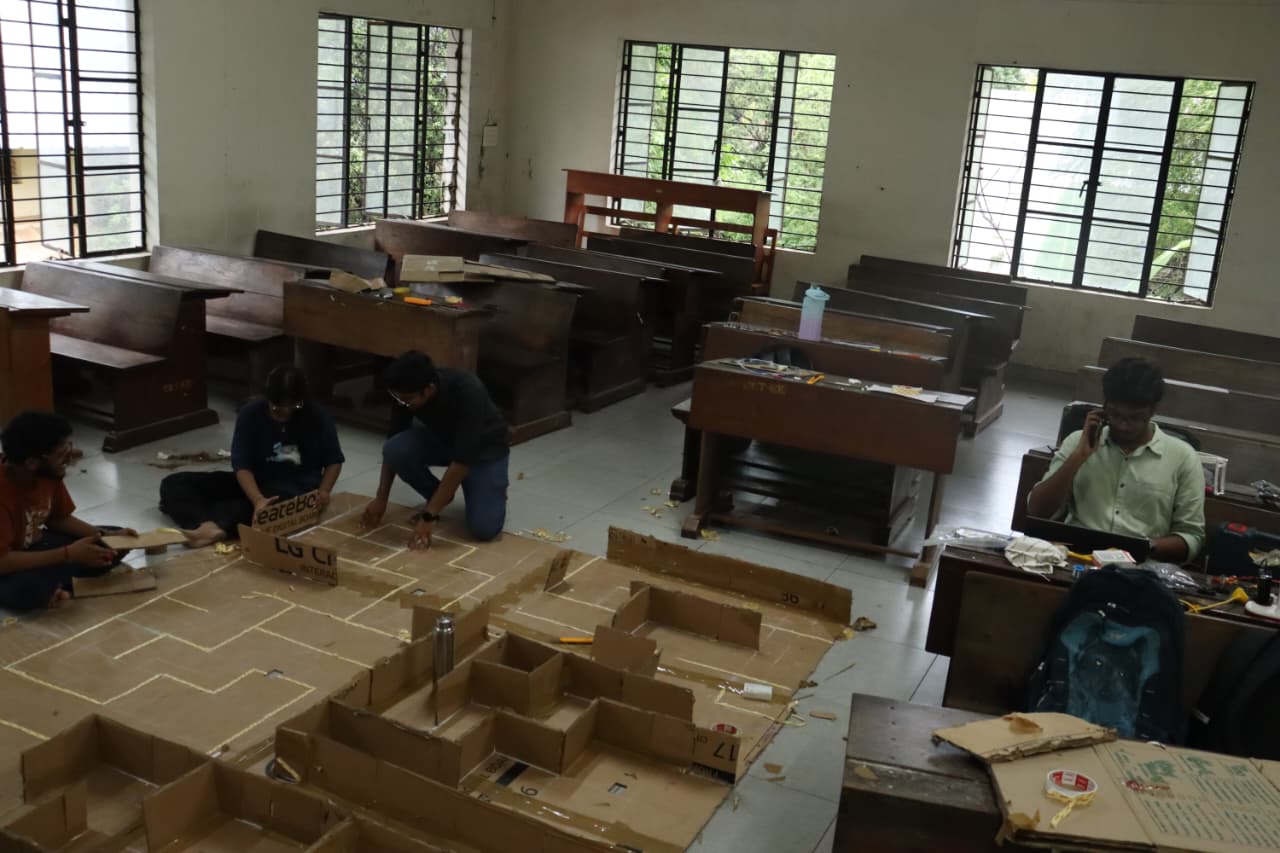
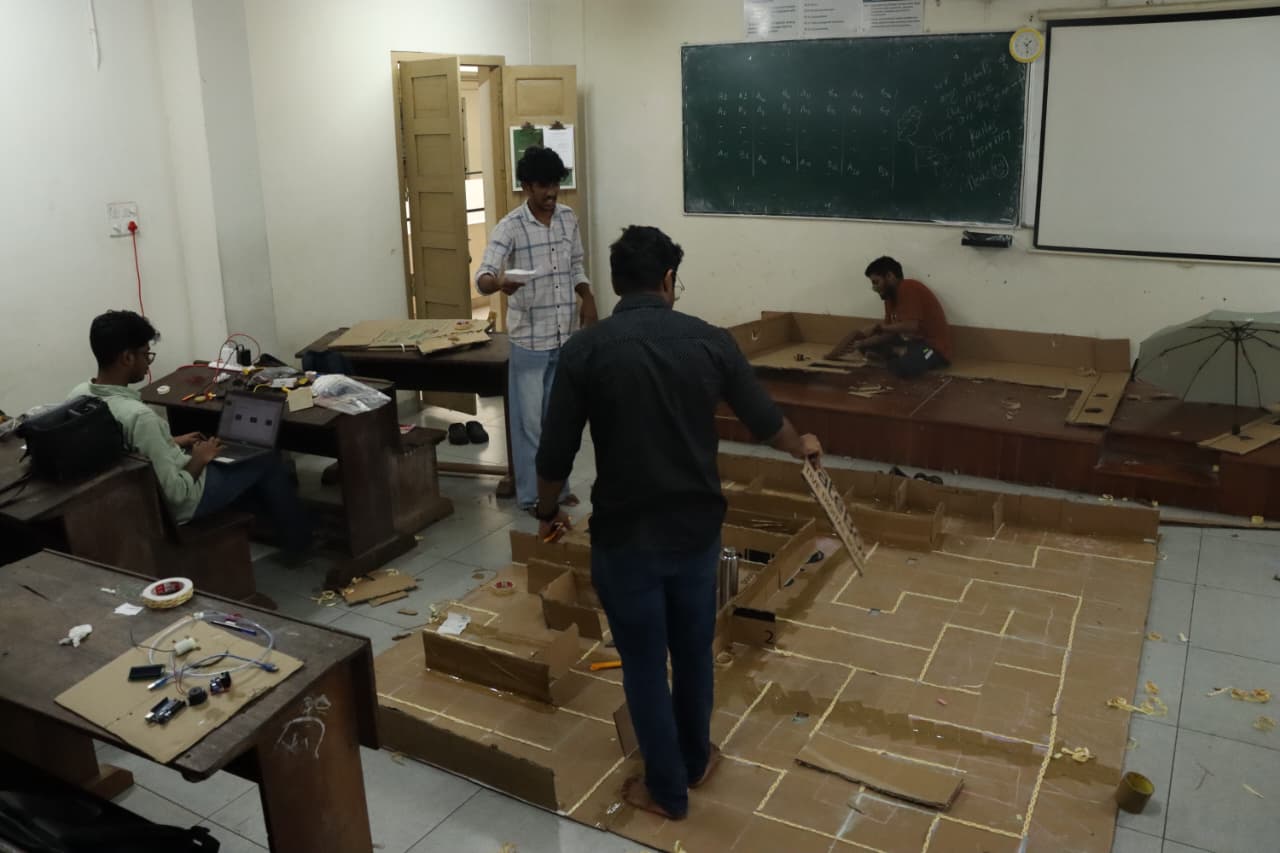
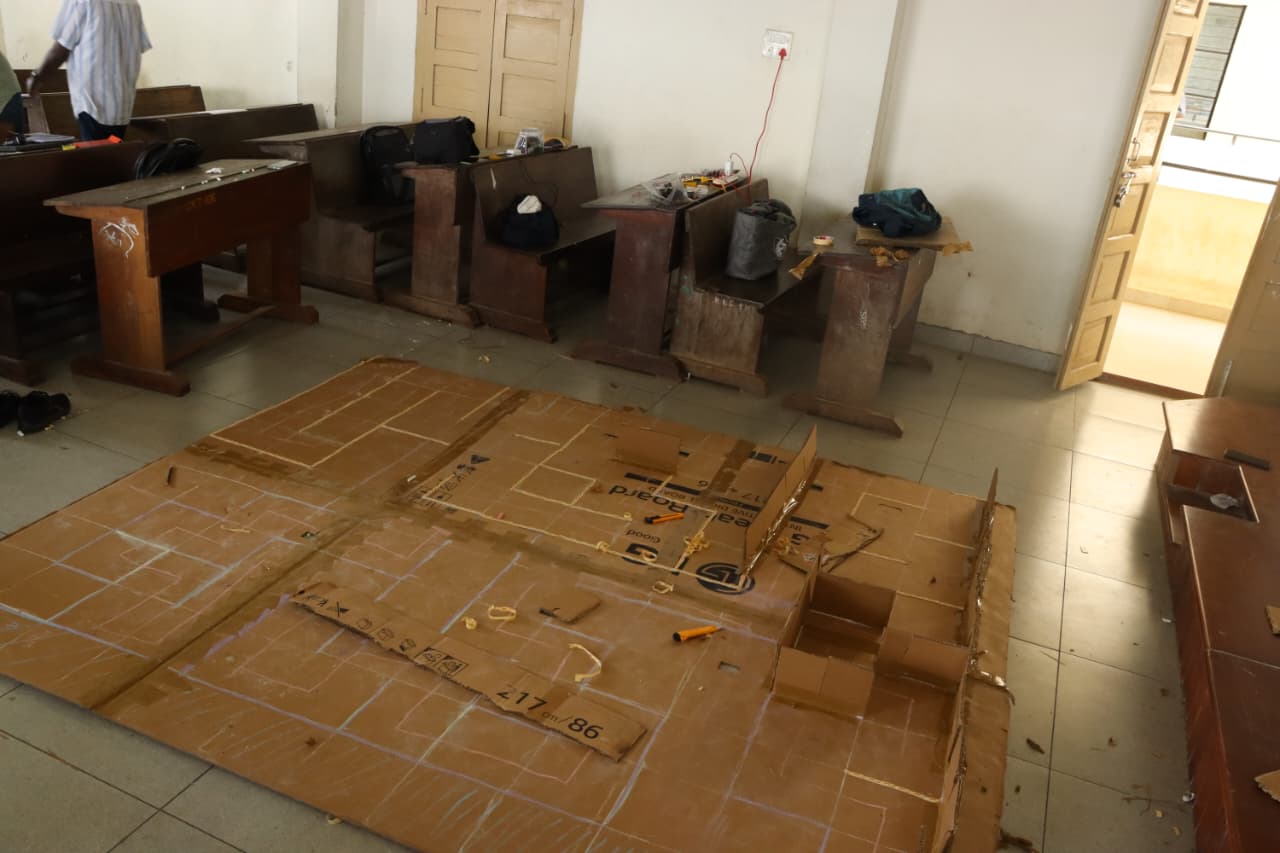
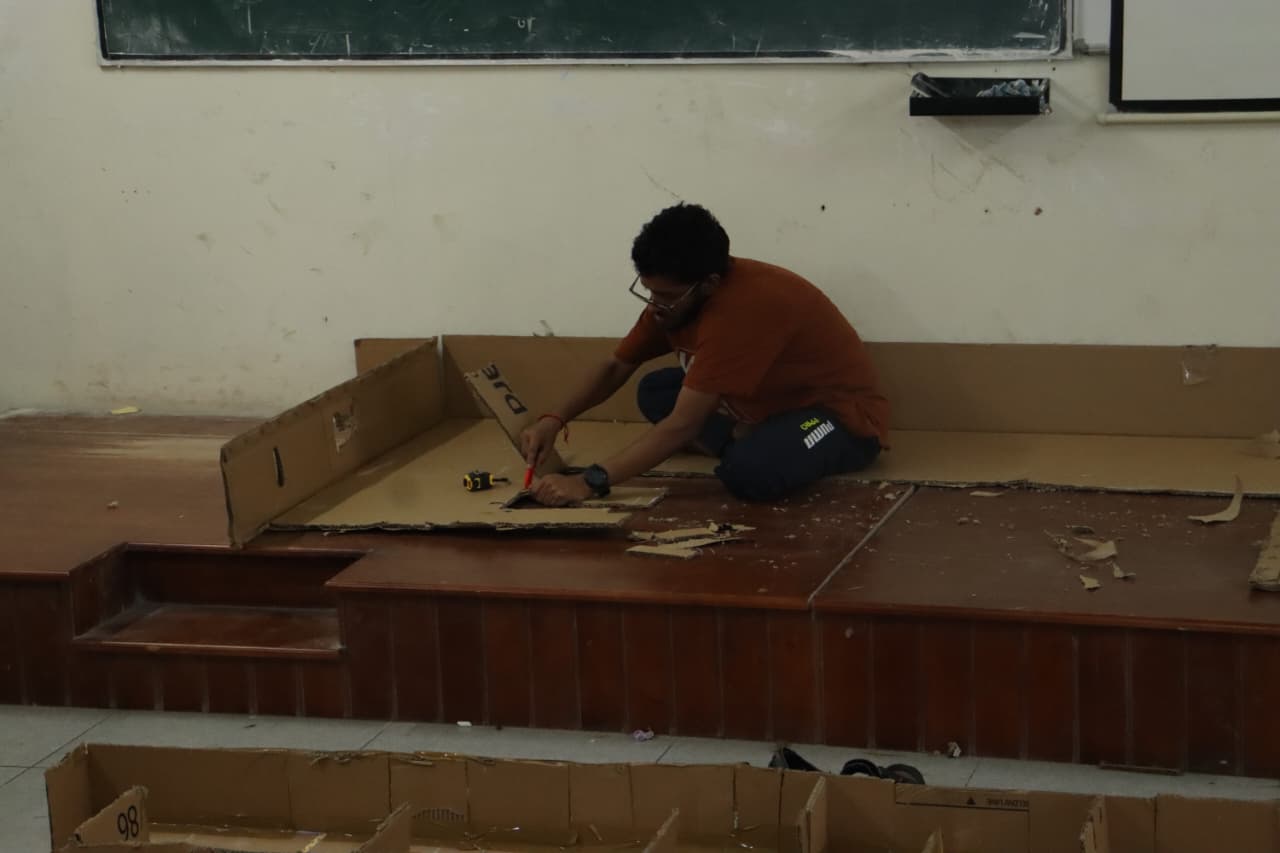
Every image tells a part of our journey
 1
 2
 3
 4
 5
 6
 7
 8
 9
10
11
 12
13
14
15
 16
 17
 18
 19
 20
 21
 22
 23
 24
 25
26
 27
 28
 29
 30
 31